MuJoCo experiments in feedback control, coupled dynamics, contact, and leg reachability.
question
prediction
experiment
observation
model update
latest notebook / 06
leg workspace
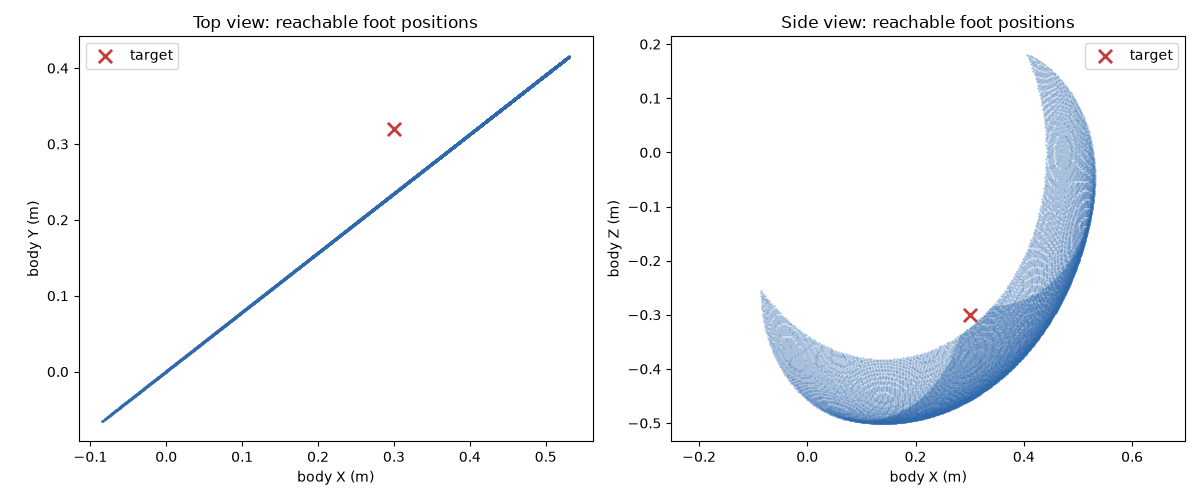
the two-joint leg misses the chosen support point by about 6.7 cm. a constrained solve with an added joint reaches the target to the printed precision. support under load remains untested.
Can the current C-1N leg reach an outward-and-down support point?
the two-joint leg misses the target by about 6.7 cm. in the constrained solve, an added joint reaches it to the printed precision. that does not yet establish support under load.
the first sweep used an incorrect ballast configuration and was stopped. a corrected fixed-foot sweep located the boundary near zero support margin and rear-contact unloading.